Research Projects
Here are the key research projects I have been working on in the field of medical robotics and computer-assisted surgery.
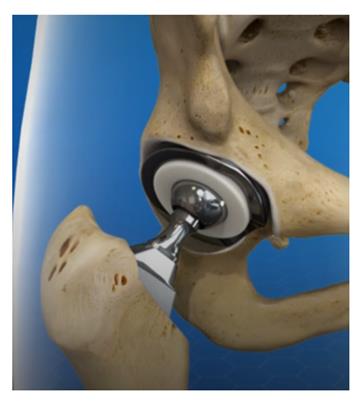
Development of a Low-Cost Minimally Invasive Robot System for Hip Replacement
Project Description
This project focuses on developing an innovative, cost-effective robotic system to help surgeons in performing minimally invasive hip replacement surgery. The system aims to assist with surgery that can automatically plan and prepare for the accurate placement of the components.
Research Outcomes
- Wang, Z., Li, T., Carmichael, M. and Huang, S., 2025. Physical Human-Robot Collaboration-Assisted Acetabular Preparation for Total Hip Replacement Surgery. In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Hangzhou, China.
- Li, T., Walker, P., Hammoud, D., Zhao, L. and Huang, S., 2025. Partial-to-Full Registration based on Gradient-SDF for Computer-Assisted Orthopedic Surgery. In IEEE International Conference on Robotics and Automation (ICRA).
Demo Video
Phantom demonstration of robotic-assisted surgical system for total hip replacement
Watch on YouTube ↗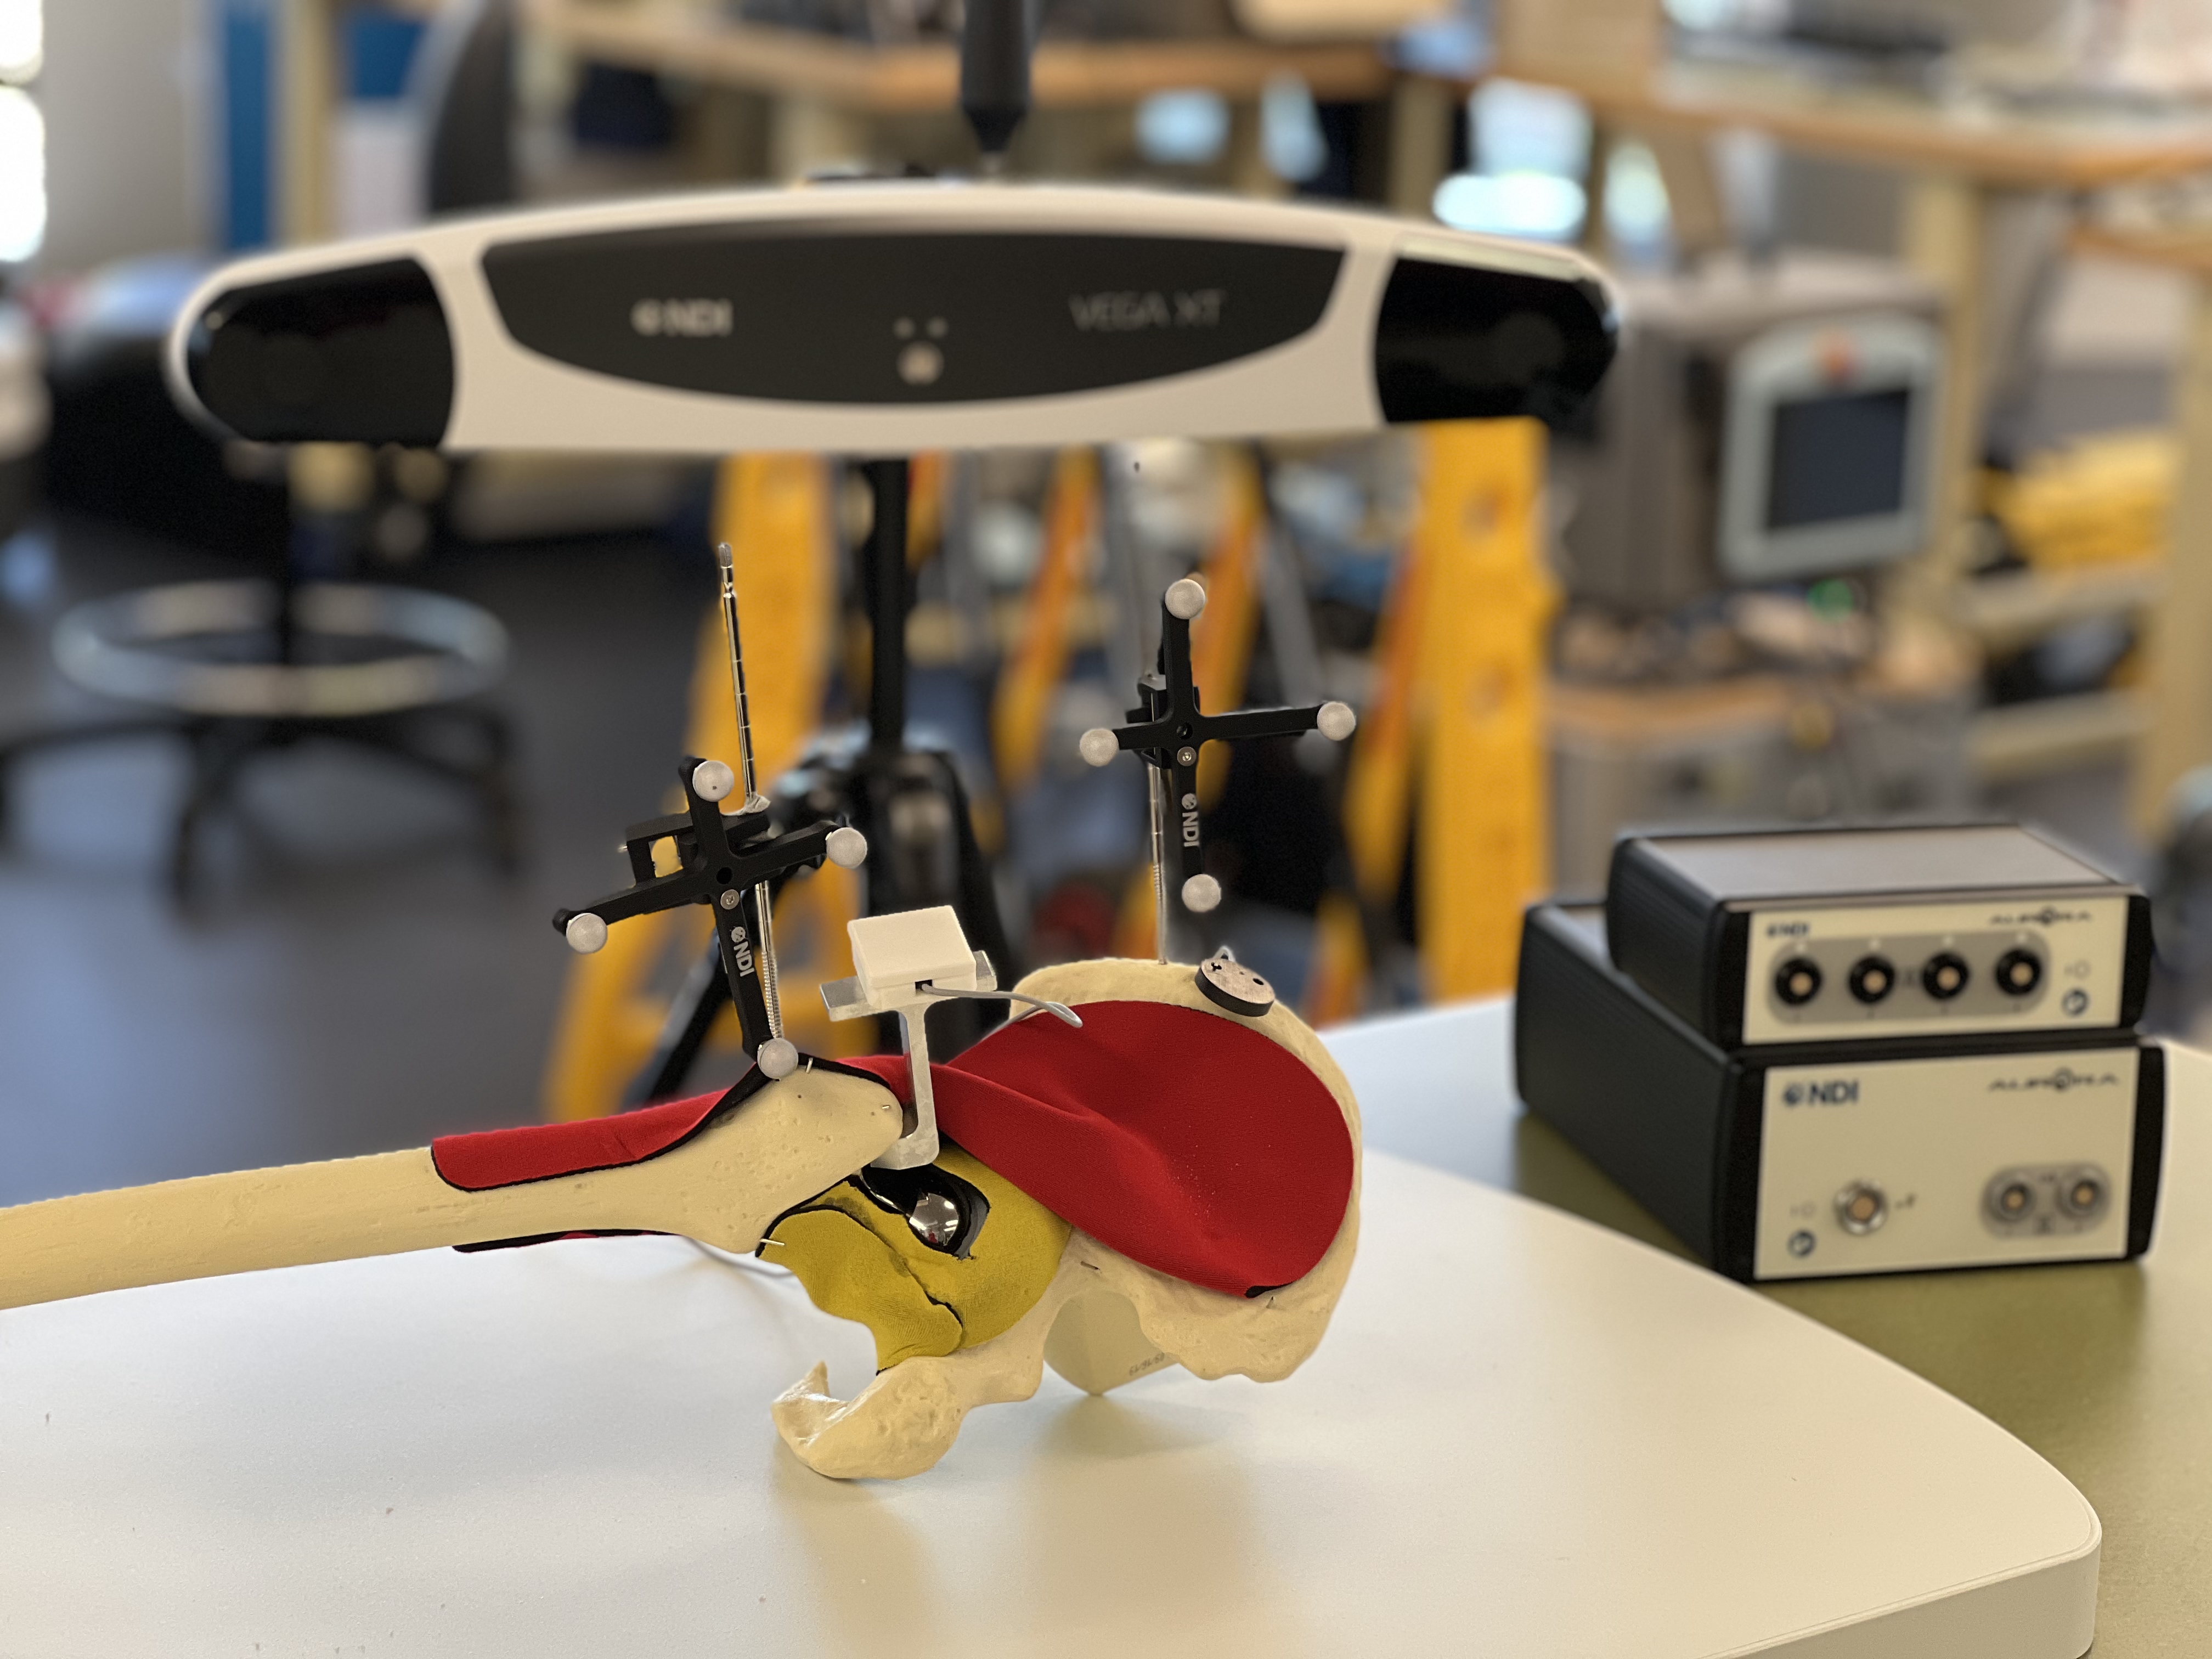
Evaluation of the Accuracy and Feasibility of using Electromagnetic Sensors in Hip Replacement
Research Outcome
- Li, T., Song, Y., Walker, P., Pan, K., van de Graaf, V.A., Zhao, L. and Huang, S., 2023, October. A Closed-Form Solution to Electromagnetic Sensor Based Intraoperative Limb Length Measurement in Total Hip Arthroplasty. In International Conference on Medical Image Computing and Computer-Assisted Intervention (pp. 365-375). Cham: Springer Nature Switzerland.
Demo Video
A Closed-form Solution to Electromagnetic Sensor Based Intraoperative Limb Length Measurement in Total Hip Arthroplasty
Watch on YouTube ↗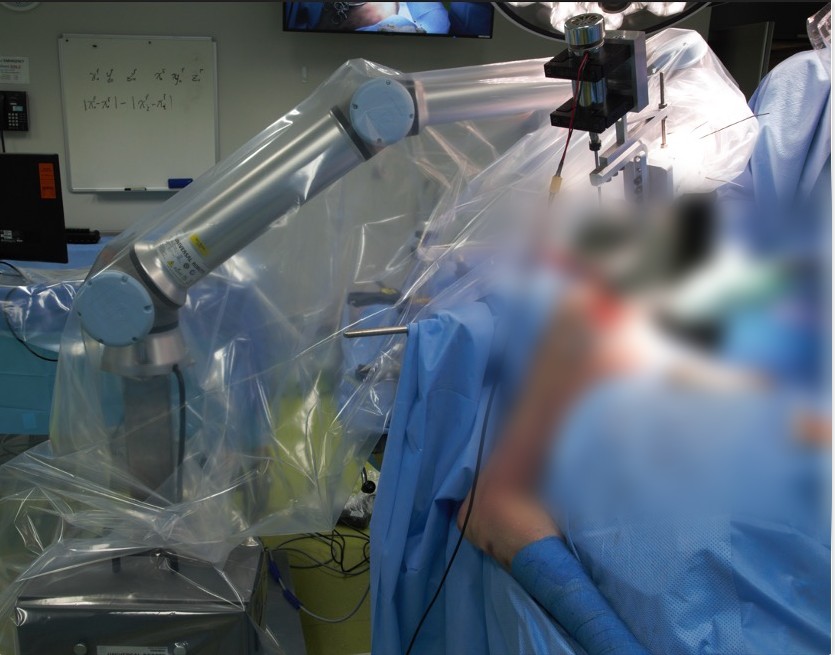
Evaluation and Improvement of the Robot Systems for Assisting Hip Replacement
Research Outcomes
- Li, T., Walker, P., Khonasty, R., van de Graaf, V.A., Yelf, E., Zhao, L. and Huang, S., 2024. Robotic‐assisted burring in total hip replacement: A new surgical technique to optimise acetabular preparation. The International Journal of Medical Robotics and Computer Assisted Surgery, 20(1), p.e2615.
- Walker, P., Li, T*., Khonasty, R., Ponnanna, K.M., Kuo, A., Zhao, L. and Huang, S., 2022. Proof of concept study for using UR10 robot to help total hip replacement. The International Journal of Medical Robotics and Computer Assisted Surgery, 18(2), p.e2359.